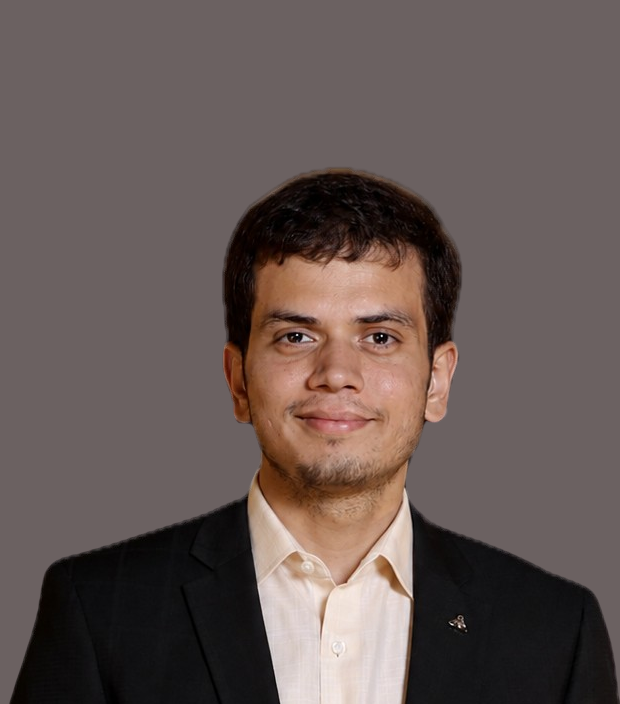
Mayank Sewlia
Assistant Professor
Department of Electrical Engineering
Indian Institute of Technology Delhi
I study motion planning and control for robotic systems. My research focuses on how multiple robots can coordinate their movements and manipulate objects together.
Experience
- Motion Planning Engineer, Neura Robotics GmBH, Germany, 2025-2026
- PhD, Electrical Engineering, KTH Royal Institute of Technology, Sweden, 2025.
- MSc, Aerospace Engineering, Technion – Israel Institute of Technology, Israel, 2020.
- BTech, Aerospace Engineering, Alliance University, India, 2017.
Research and publications
Manifold-constrained Motion Planning for Cooperative Manipulation
Under review
Students
Master’s
- Yiyu Sun (2026) — Kinodynamic Trajectory Generation and Tracking. Co-supervised with Dženan Lapandić.
- Hampus Carlens (2024) — Manipulation on the Move for Pick-and-Place Tasks. Joint supervision with Ericsson Research. Thesis
- Rufus Cheuk Yin Wong (2024) — Motion Planning of Redundant Manipulators. Co-supervised with Adrian Wiltz. Thesis
- Sara Gomiero (2023) — Sampling-Based Synthesis of Controllers for Coupled Agents under Signal Temporal Logic Specifications.
Courses
- JR302: Robotics Technology — Planning Module. Autumn 2026
Teaching
- EL1020: Automatic Control — Teaching assistant, KTH. Bachelor’s level, 7.5 ECTS; Autumn 2022 and Autumn 2024.
- EL2520: Control Theory and Practice — Advanced Course — Teaching assistant, KTH. Master’s level, 7.5 ECTS; Spring 2023.
Office
- Room III-B1, Block III, IIT Delhi, Hauz Khas, Delhi 110016, India.
- Email: sewlia@iitd.ac.in