The first Assignment in DSL810: Prototyping in IoT, was to come up with a proposal for the course project. The project should use both uC programming, embedded programming, electronics (input+output devices) skills, as well as UI in laptop/mobile app. I decided that I'll be working on the project, "Hand Gesture Controlled Wifi Robot, with Animesh Singh.
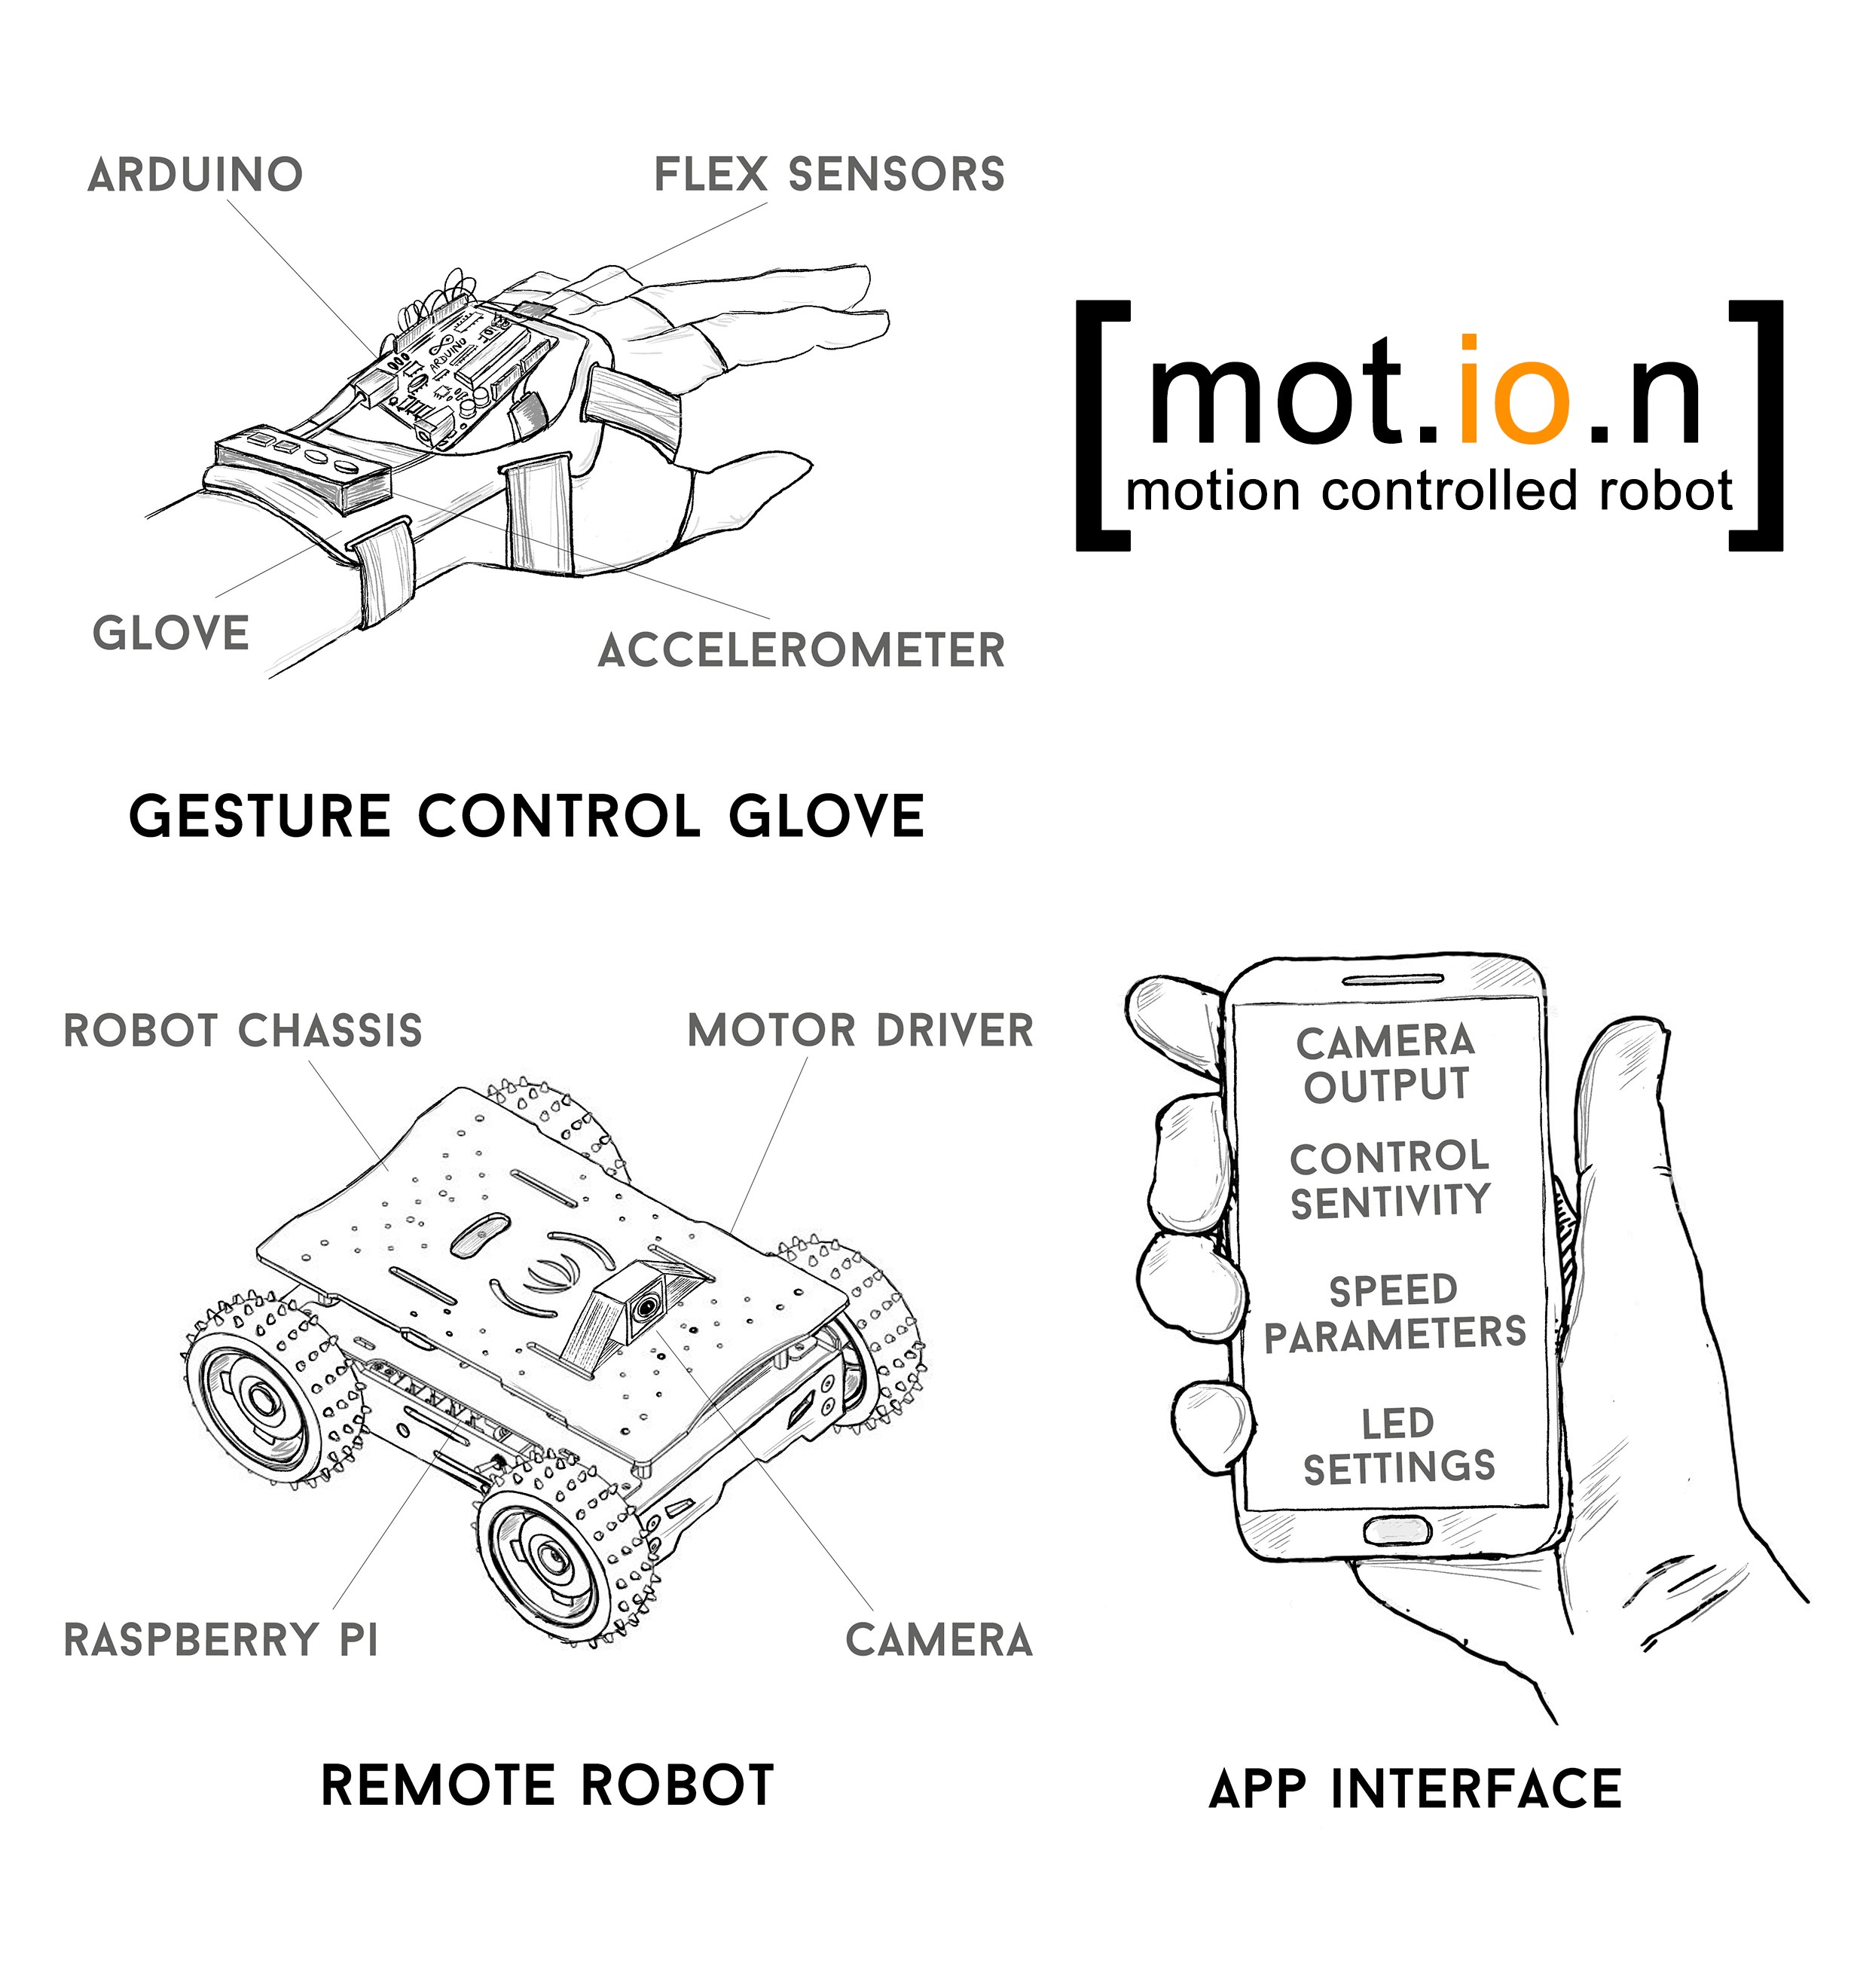
Project Poster
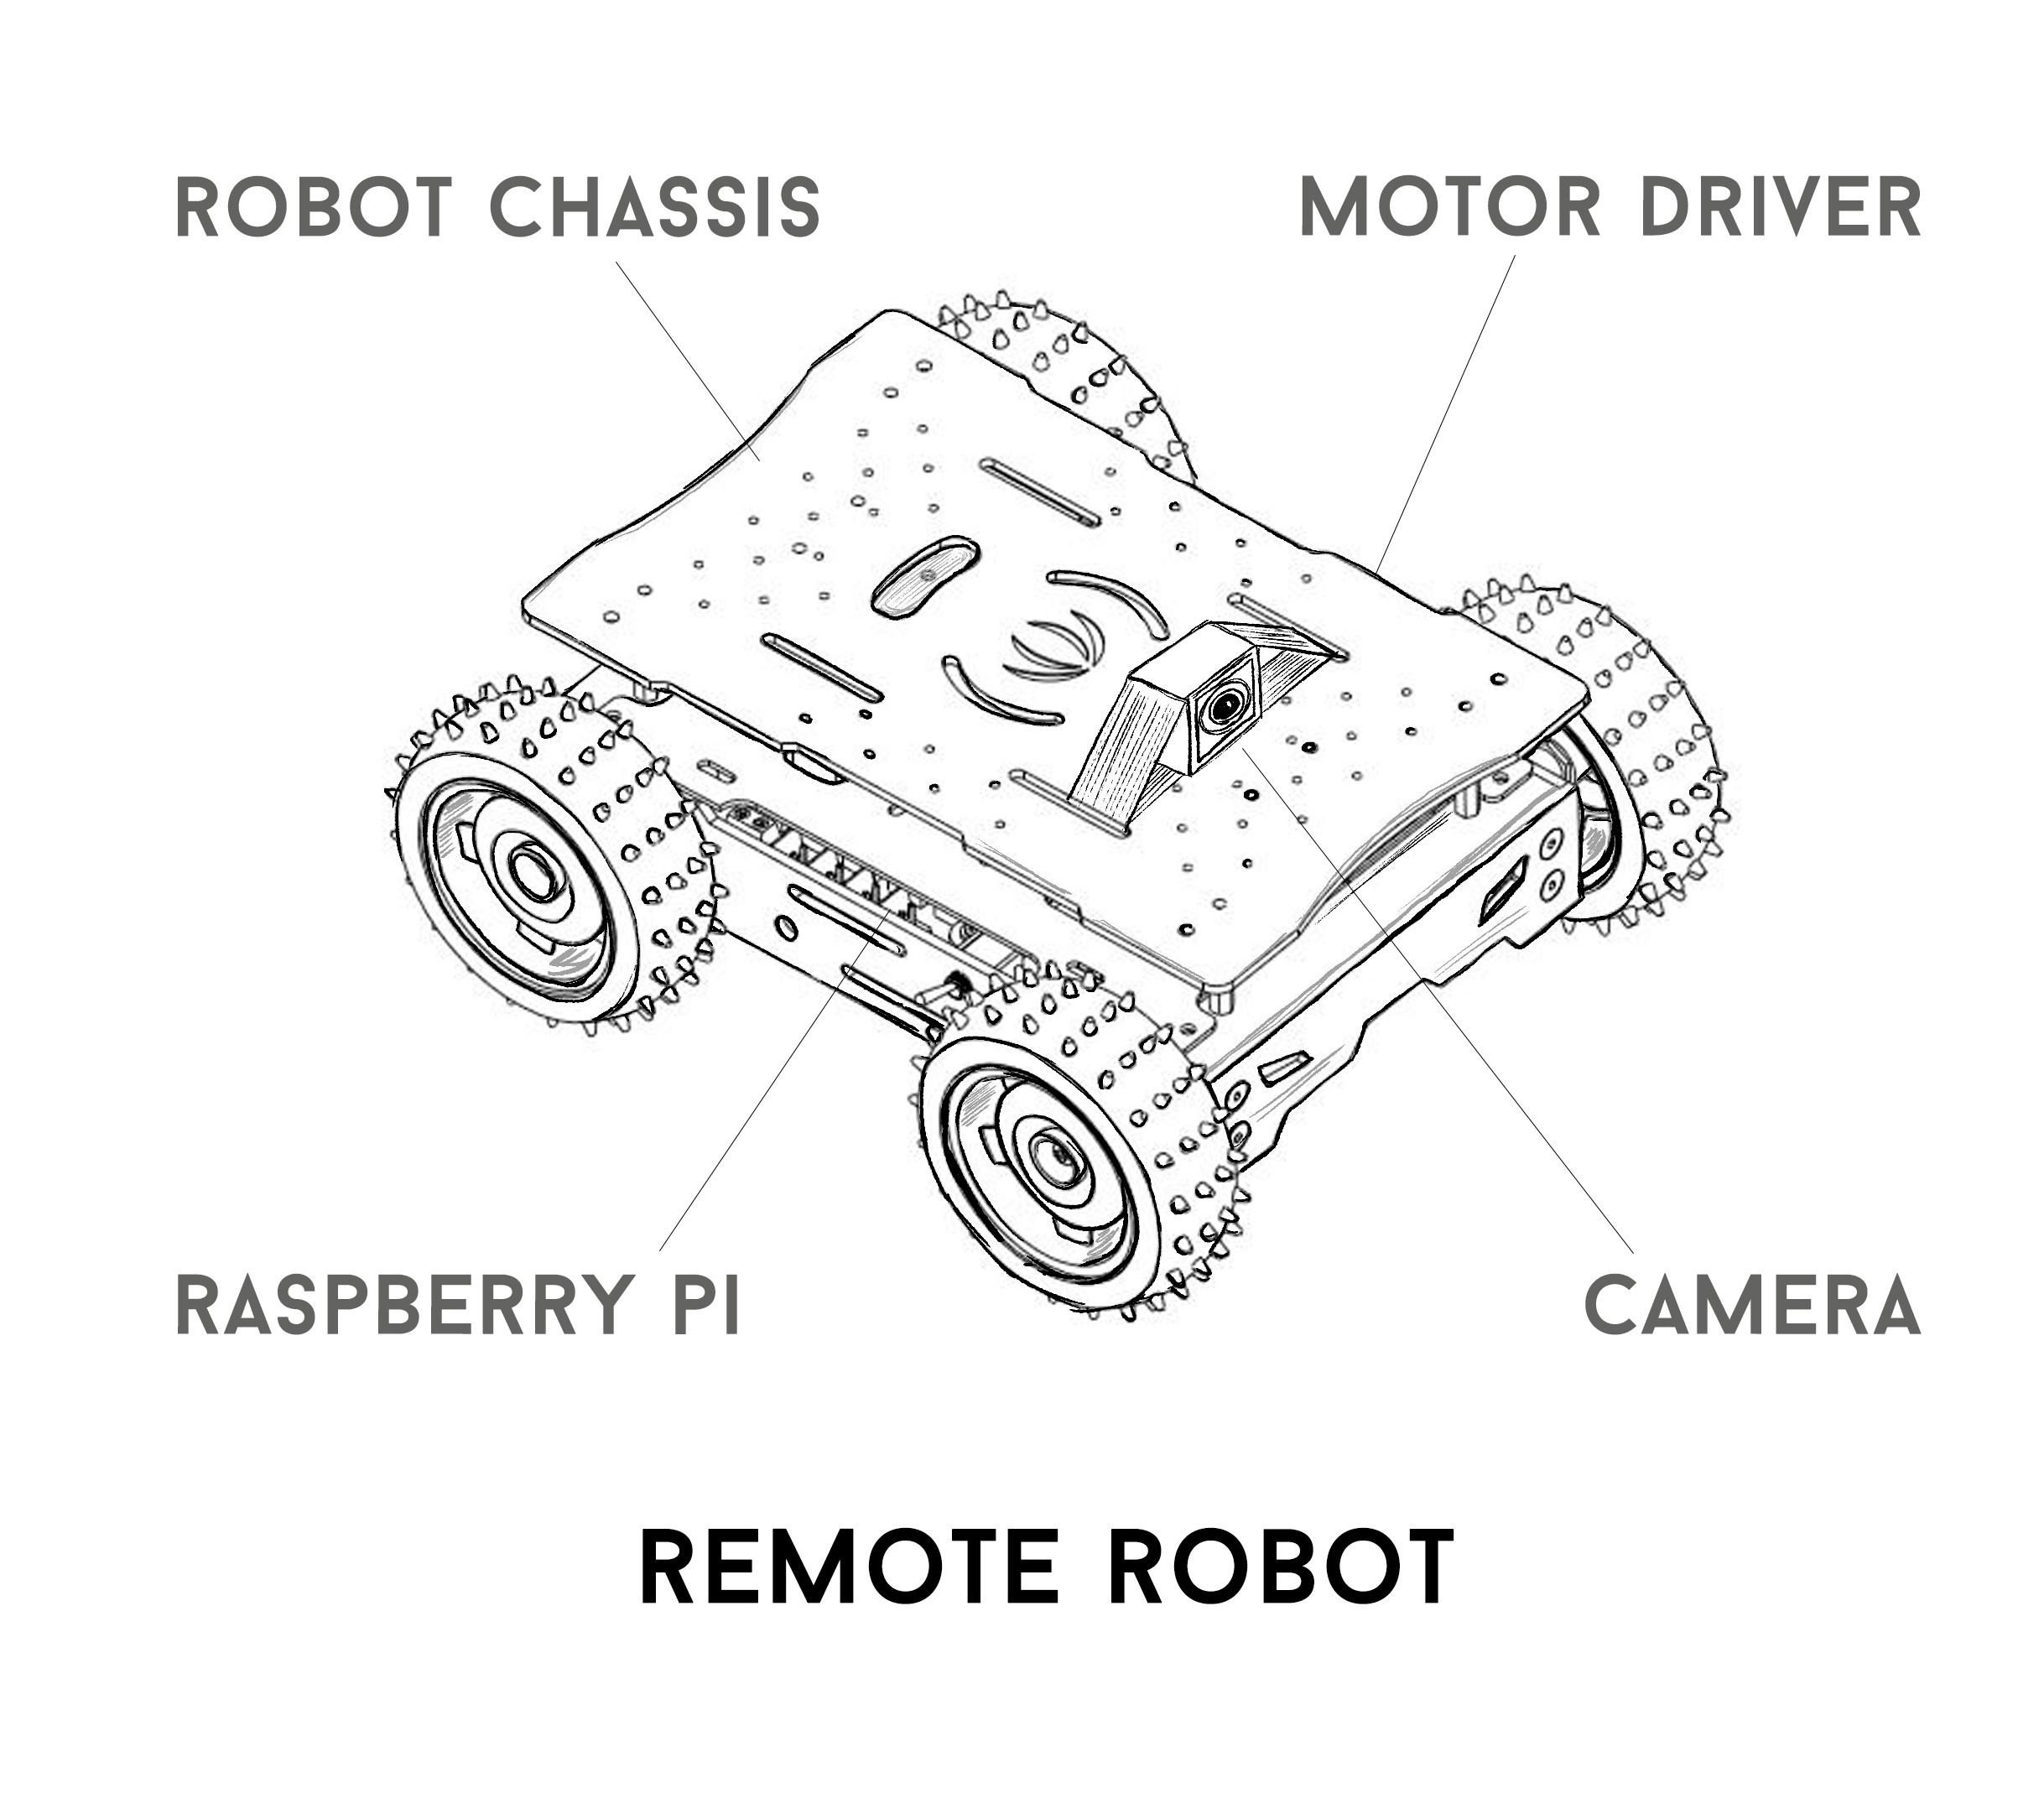
Components
Hand Gesture Controlled WiFi Robot
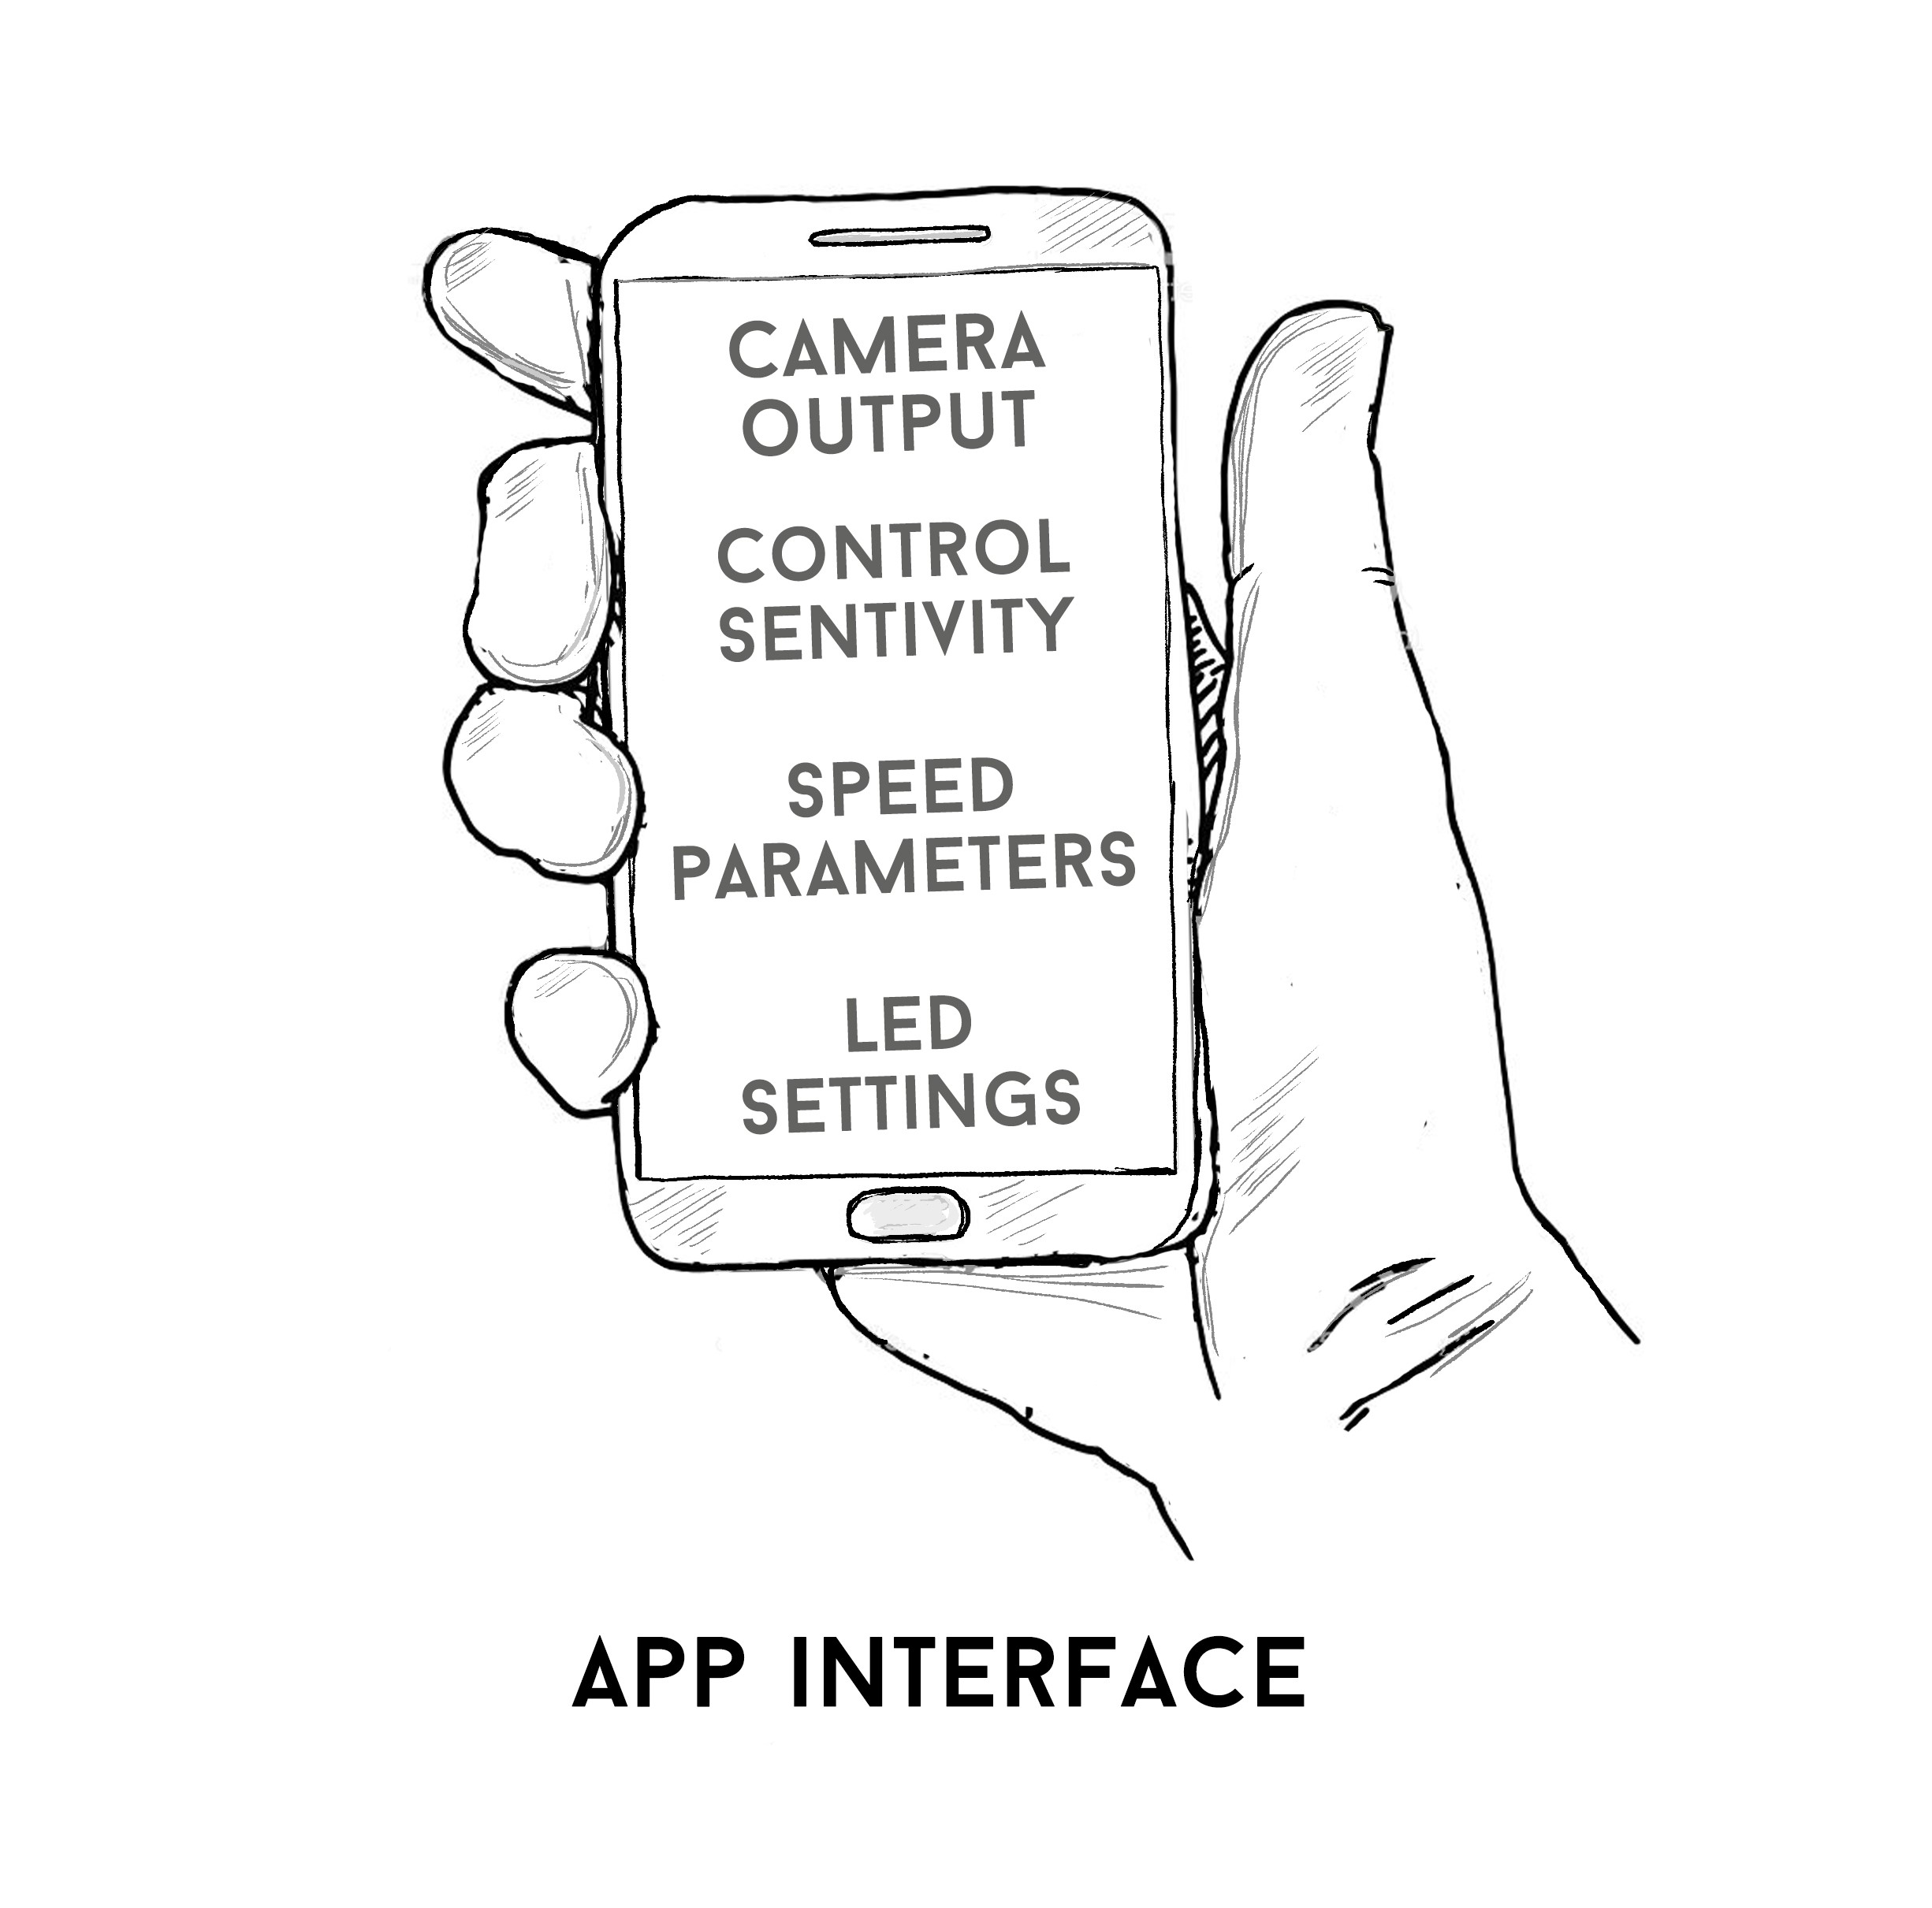
The aim of the project is to build a Raspberry Pi Rover Robot, which can travel through rough terrain and can be controlled using hand gestures. Apart from the movement, the other settings of the robot can be controlled by a mobile app and the website. We will also fit a camera on the robot, and the display could be seen on the app.
• Wireless controlled robots are useful in applications like remote surveillance & military.
• Hand gesture controlled robot can be used by physically challenged in wheelchairs.
• Hand gesture controlled industrial-grade robotic arms can be developed.
• Hand gesture controlled robots can also be used for earth and space exploration.
Approach
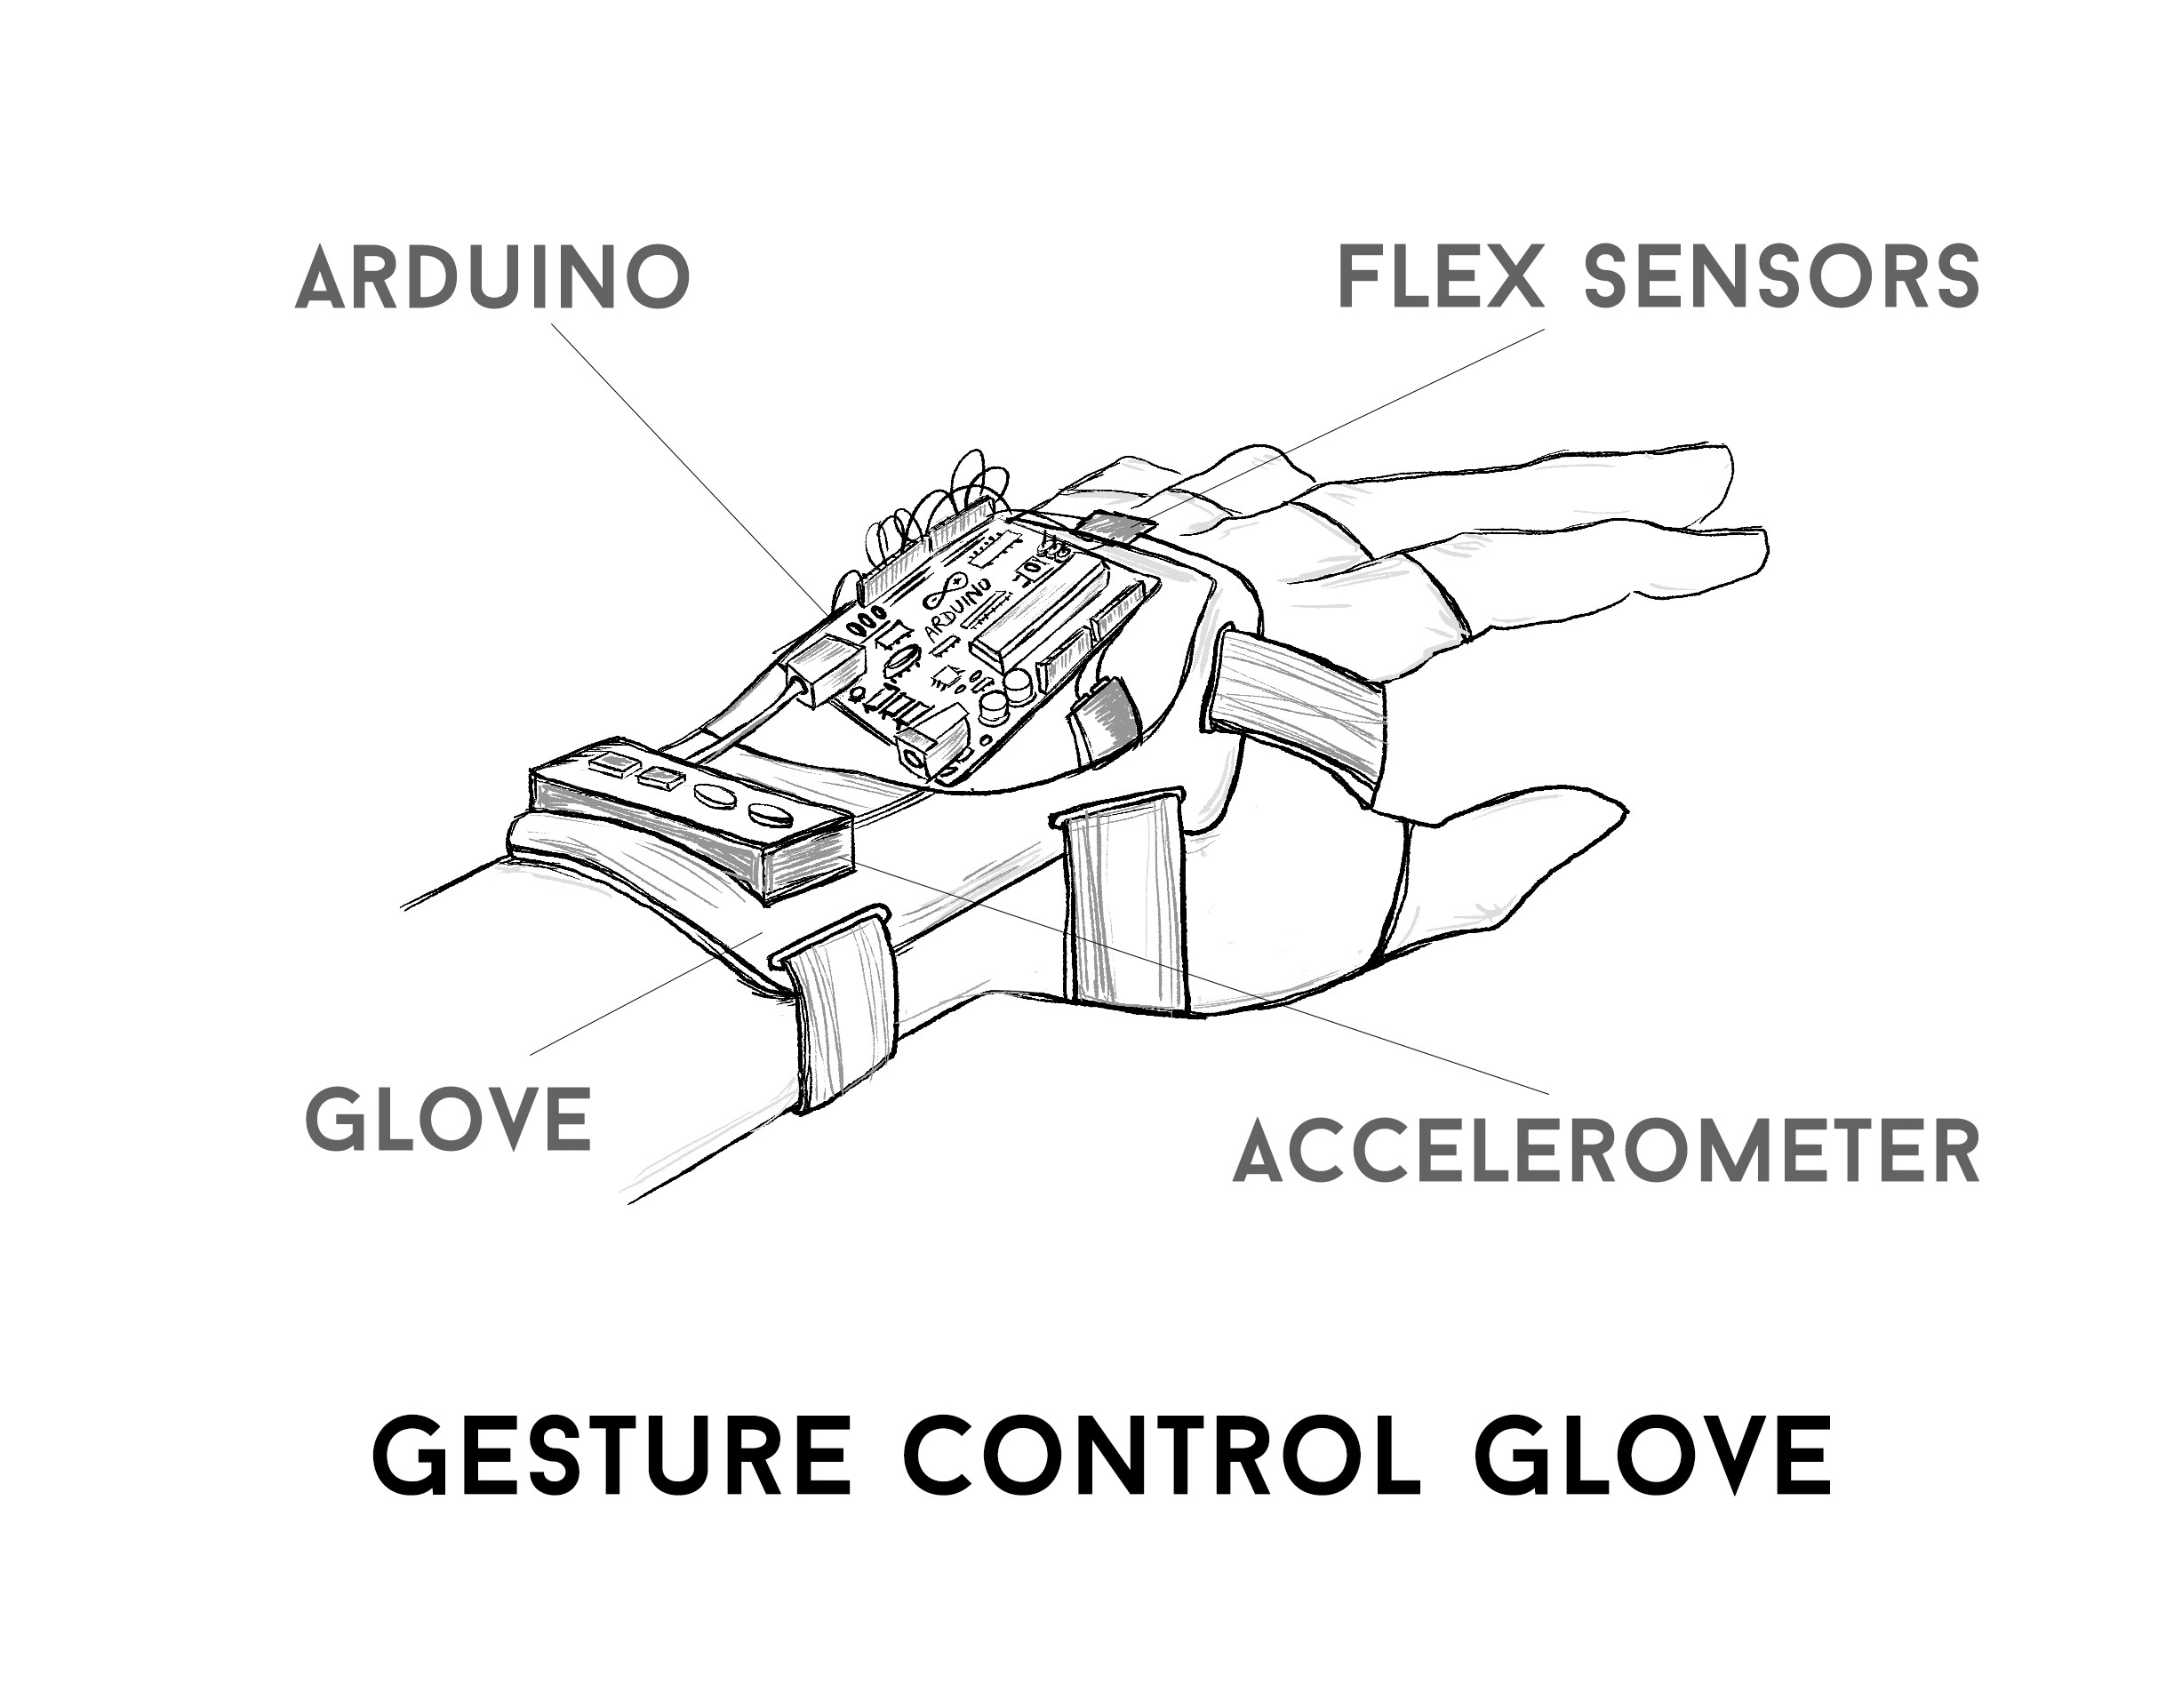
We will use a control glove which acts as a gesture sensor to drive the Robot. The gesture sensor will have both an accelerometer and a flex sensor to control the status and direction it should be going. The flex sensor activates the Robot and the tilt of the accelerator determines the direction it should move.
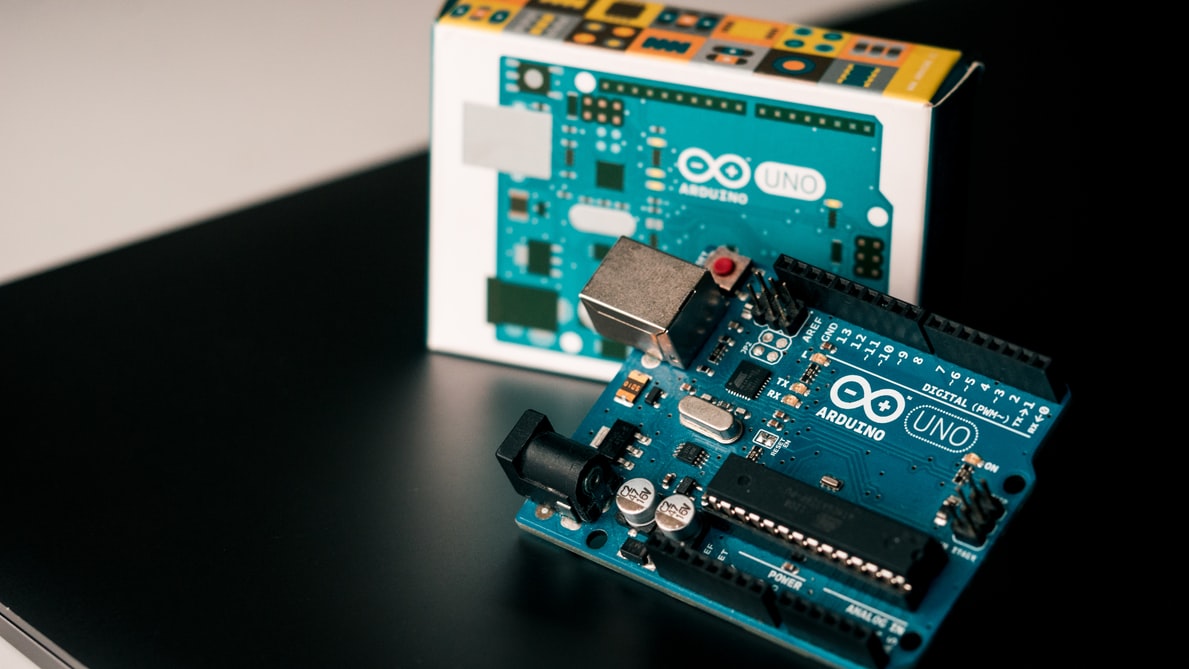
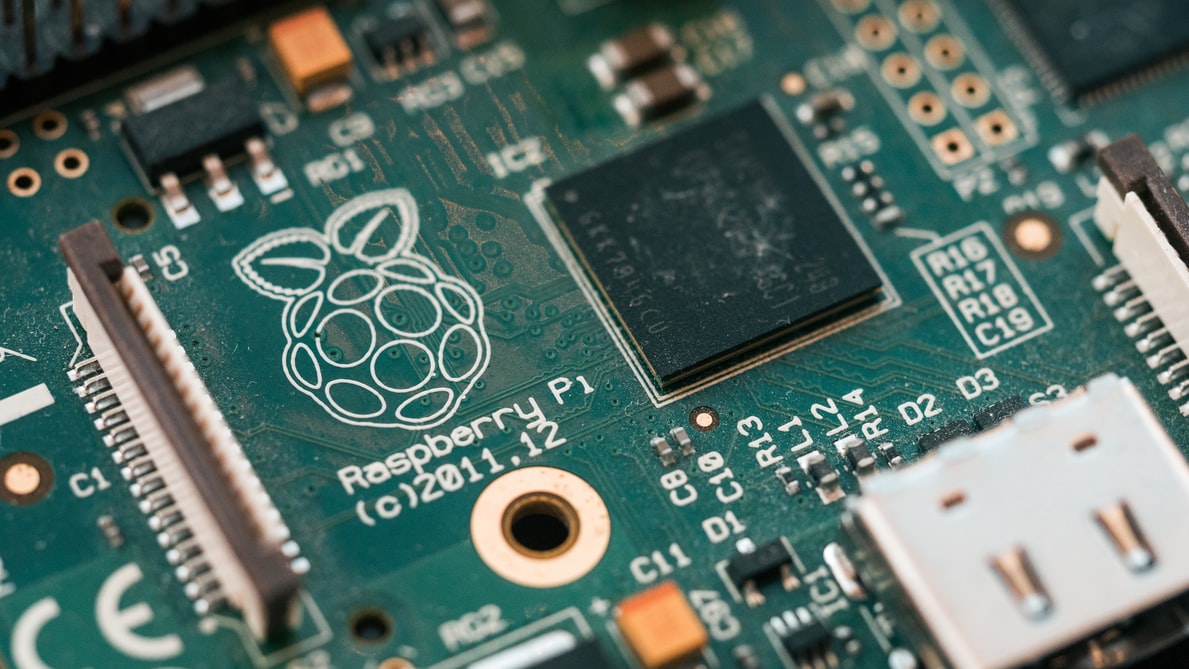
We will use Raspberry Pi and Arduino to create our Gesture Controlled Robot. Arduino to make the control glove, which will detect the hand gestures and send the data to Robot via WiFi. We will use a Raspberry Pi to make the Robot, which will receive the data sent from the Arduino, process them and control the bot.
Components Required
Gesture Controller Glove
• Gloves
• Accelerometer
• Flex sensor
• Any Arduino Board with Wi-Fi connectivity
• Breadboard
• Resistor
The Robot
• Robot Chassis
• L293D motor driver
• Raspberry Pi or another Arduino (for controlling the robot)
• Breadboard
• Resistor
Skills Used
Microcontroller + Embedded Programming
A major skill that would be used in the design of both the components i.e. the glove controller and the wireless robot. We plan on using a wifi-enabled Arduino board for the glove and using a Raspberry Pi for controlling the robot.
Electronics (Input+Output Devices)
Many sensors will be required as input devices including accelerometer, flex sensors, proximity sensors, etc. Output devices will be motor drivers, small wheels for the robot, LEDs, displays, etc.
CAD & Additive/Subtractive Fabrication
We want to produce & construct the robot chassis ourselves and for that, we would require CAD and 3D printing facilities.
UI in Mobile App
We plan on building a remote controller for setting some functionalities on the robot wirelessly through a mobile app. An example could be setting the speed, LED settings, control sensitivity, etc.
Anticipated Challenges
• Both of us are attempting such a project for the first time, hence a challenge in this task would be to learn and effectively apply all the skills that are required to bring this project to completion, and more.
• We plan on producing & constructing the robot chassis ourselves using CAD and 3D printing, both of which are new skills and we may face some roadblocks in the process.
• App development is another skill we have no prior experience at, hence that can be a potential challenge as well.
• We have a fair amount of wireless communication being used in different components of our project - the successful execution of which can pose a challenge for us.
Timeline
February: Procurement of materials and initial completing the loop approach to prototyping for the control glove and remote robot.
March: Working on additional features for control glove and remote robot, making the UI for the app and integrating with remote robot.
April: Refining the prototype and testing.
Future Scope for the project
In the future, the project can be extended and a smartwatch app can be made for the user, so he can control the movement as well as the other settings through his hand entirely.